Roller vehicle monitoring systems put the numbers in front of the operator while the machine is still working. Compaction and grading are two of the most repetitive, operator-judgment-dependent tasks on a construction site — and two of the easiest to get wrong without real-time data. A road roller operator historically judges compaction density by pass count and feel; a bulldozer operator judges blade depth and grade by eye. CF-Device’s rugged vehicle terminals show the data the machine already produces, in one cab display.
TL;DR
- Road rollers: real-time pass count, vibration frequency, and density data replace operator “feel”
- Bulldozers: live grade/depth readouts relative to design surface replace judging by eye
- The terminal displays and records what the machine’s own sensors output over CAN; it does not replace the sensors or control the blade
- Same rugged hardware requirements as other heavy equipment — dust, vibration, sun, temperature swings
- Running on the same platform as fleet management unifies utilization, maintenance, and grading data
Road Roller Compaction Monitoring
Mounted in the cab, a rugged vehicle tablet connected to the roller’s onboard sensors via CAN bus can display real-time compaction data — pass count, vibration frequency, and estimated density — directly to the operator, instead of leaving compaction quality to be judged after the fact. Which of those values appear depends on what the roller itself outputs: the terminal reads and shows the machine’s data, it does not measure density on its own.
Roller Vehicle Monitoring Systems: What Actually Reaches the Terminal
Buyers searching for a road roller compaction monitoring setup or a compaction monitoring system are usually asking one practical question: what signals can I get from my roller? The answer is set by the roller’s own control system. A roller that already outputs pass count, drum vibration and frequency over CAN gives the terminal something to show; a roller without those outputs needs a sensor retrofit, and that is not something a display can substitute for. The terminal’s part is the other half of the job: reading the bus reliably, logging each pass with a position and a timestamp, and showing the result in a form the operator can act on during the pass. The CAN side is covered in CAN bus & J1939 integration. Compaction rigs often have more than one bus to reach, so the channel count matters: the VCM V12 PRO offers up to four CAN channels with IP67 sealing, while other models have fewer, so confirm the count for the machine.
Bulldozer Blade Grade Readouts
For bulldozers, the same tablet platform can integrate with blade position sensors to give the operator live grade and depth readouts relative to a target design surface. The automatic blade control, where fitted, is done by the dozer’s own system; the terminal is the display and the record. The challenge is closely related to our guide on excavator slope grading and depth assistance, and how accurate the position has to be for each machine type is set out in GPS for heavy equipment: which accuracy tier each machine needs.
Mixed Fleet Bulldozer Automation: One Display Across Machines
Mixed fleet bulldozer automation is the situation most contractors actually face: dozers, rollers and excavators from different manufacturers, each with its own display and its own way of showing grade or compaction. The case for a common terminal is not that it automates the blade — each machine’s own control system does that — but that the operator, site manager and fleet system see the same layout and the same kind of record from every machine. That is what makes it practical to move an operator from a roller to a dozer without retraining on a new screen, and to compare grading and compaction performance across the fleet.
What Real-Time Data Replaces
| Task | Old Method | With Real-Time Terminal Data |
|---|---|---|
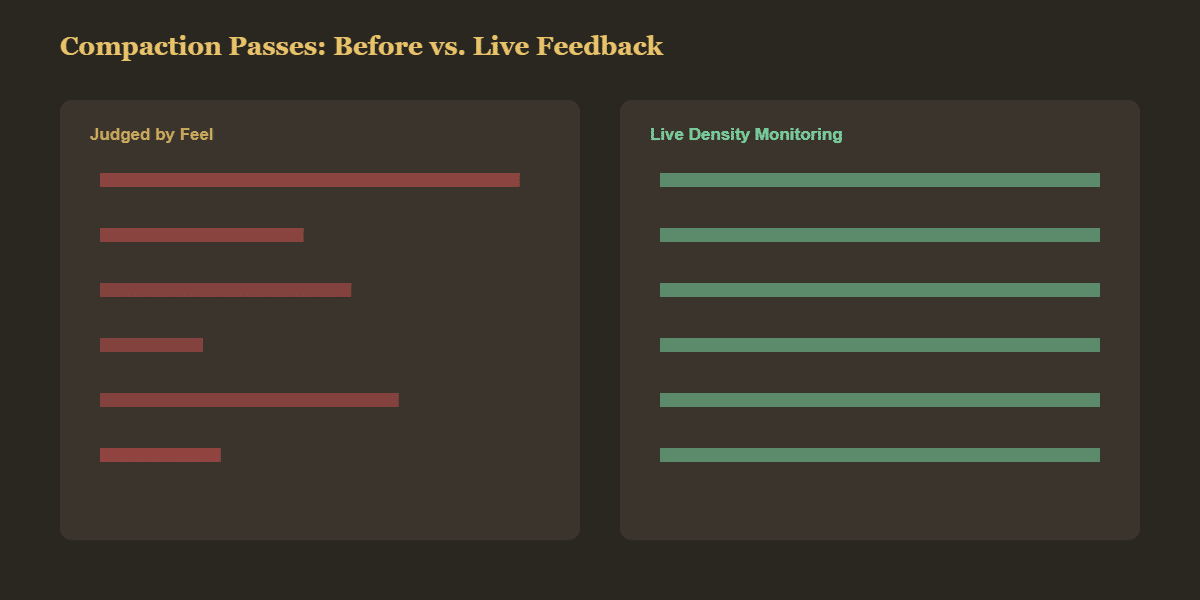
| Compaction density | Pass count + operator feel | Live vibration frequency + estimated density |
| Blade grade/depth | Visual judgment vs. stakes | Live readout vs. design surface |
| Rework detection | Discovered after inspection | Flagged during the pass |
An Illustrative Deployment Example
Picture a road-building crew running three rollers on a highway resurfacing job that relies on spot-check density tests after each section is compacted — meaning under-compacted sections are only caught after paving has already started nearby. With CAN-bus-connected tablets displaying live vibration and pass-count data, operators can see under-compaction in real time and add passes before moving on, reducing rework call-backs — the same CAN-bus integration covered in our CAN bus & J1939 guide.
Why This Belongs on the Same Hardware as Everything Else
Compaction and grading equipment operates in the harshest conditions on a job site — dust, vibration, direct sun, and wide temperature swings. This is exactly the environment IP67/MIL-STD-810-rated rugged tablets are built for; sealing runs from IP65 to IP67 by model, so match it to the machine. Running this data through the same platform used for MDM remote device management and fleet management means equipment utilization, maintenance alerts, and grading performance all live in one system.
The Practical Payoff
For contractors running mixed fleets of rollers, dozers, and excavators, the value isn’t just the individual sensor readout — it’s that every machine on-site reports through the same rugged tablet platform, giving site managers one consistent view instead of a patchwork of vendor-specific displays. The four jobsite roles a construction terminal has to cover, and how the spec differs for each, are compared in tablet for the construction industry. The same real-time monitoring principle applies to other precision-dependent applications, including Mining: Rugged Terminals for the Harshest Working Environment, where equipment vibration and dust conditions demand the same durability standard. For the full hardware specification sequence, see the rugged vehicle tablet hardware buyer’s guide.
Common Questions
Does this require special sensors on the roller or dozer, or does the tablet do the sensing?
The equipment needs compatible onboard sensors (vibration, blade position); the tablet displays and processes that data via CAN bus — it doesn’t replace the sensors.
Can one tablet handle multiple equipment types on the same site?
Yes, provided each machine has compatible sensor integration — the terminal platform itself doesn’t change between roller, dozer, or excavator use.
Is real-time compaction data a substitute for lab density testing?
It reduces how often rework is discovered late, but doesn’t necessarily replace formal density testing required for compliance sign-off on some projects.
What’s the main hardware requirement beyond ruggedness?
Reliable CAN-bus integration with the specific machine’s onboard sensor systems — confirm compatibility and the number of CAN channels before deployment.
Does the terminal control the dozer blade?
No. Where automatic blade control is fitted, the dozer’s own control system does it. The terminal shows the grade and depth readouts and records them, which is what lets a mixed fleet use one display across machines.
Interested in specs or a quote? Contact our team to discuss compaction and grading terminal options.